 zishengelectric


news
News Center
Providing high-quality power to the world
Search productSearch post
news
Providing high-quality power to the world
Transformer OLTC control interface design connects the mechanical tap changer, motor-drive mechanism, automatic voltage regulator, protection relays, SCADA, station auxiliary supply, and operating philosophy. The transformer supplier can provide a proven on-load tap changer, yet the substation may still fail commissioning if raise and lower commands are reversed, tap position scaling is inconsistent, parallel units use incompatible control modes, or alarm and blocking signals have no agreed destination.
For an EPC project, the interface must be closed before control schematics and panel manufacturing are released. IEC 60214-1 covers performance requirements and test methods for tap changers and their motor-drive mechanisms, while the project must define how the installed system regulates voltage. This guide gives EPC designers, owners, protection engineers, and commissioning teams a practical method for specifying, reviewing, testing, and handing over the complete OLTC control chain.
Begin with the network purpose. An OLTC may regulate a remote bus, maintain a local secondary voltage, compensate feeder drop, coordinate with shunt reactive devices, or share reactive load between parallel transformers. These objectives are not interchangeable. State the controlled voltage, measurement source, target band, time delay, line-drop compensation basis, tap limits, and responsibility for manual and automatic modes.
Document every operating state: local manual at the motor drive, local electrical control, remote manual from the control room, automatic control by AVR, parallel-control mode, and maintenance isolation. Define the priority among modes and the exact transfer behavior. Operators need to know whether selecting local disables remote commands, whether automatic mode resumes after auxiliary-supply restoration, and which alarms remain active when the drive is isolated.
The transformer supplier typically owns the tap-changer mechanism, motor drive, limit switches, local controls, and internal wiring to terminal blocks. The EPC team may own the AVR, bay controller, SCADA database, voltage transformers, interposing relays, control cables, DC or AC supplies, and station operating procedures. Put these responsibilities in an interface matrix. A signal without a named origin, destination, voltage, contact state, and test owner is not a closed interface.
The approved transformer data sheet should state the regulating winding, rated tapping position, tapping range, number and size of steps, tap sequence, voltage per tap, current rating, insulation level, through-current capability, and intended operating duty. Confirm whether the mechanism is a selector switch or diverter-switch arrangement and identify the oil compartment, filtration connection, pressure relay, and maintenance access where applicable.
For the motor drive, record supply voltage and tolerance, motor starting current, heater supply, control voltage, protection devices, torque or mechanical protection, operation counter, position transmitter, local indication, hand crank interlock, emergency stop if supplied, and terminal arrangement. Confirm the behavior at upper and lower limits and after an incomplete operation. A mismatch between the selected auxiliary supply and the station design can surface only when the first movement is attempted on site.
| Interface decision | Design evidence | Failure if unclear | Acceptance check |
|---|---|---|---|
| Voltage measurement | VT source, ratio, fuse supervision, phase selection | AVR regulates the wrong bus or uses a failed signal | Secondary injection and end-to-end polarity check |
| Raise/lower commands | Cause-and-effect, contact logic, pulse duration | Tap moves opposite to voltage correction | Command every mode with position observed |
| Tap position | BCD, resistance, mA, transducer range or protocol map | SCADA and AVR display different positions | Verify all positions or an agreed representative set |
| Parallel control | Master-follower, circulating-current or reactive-current method | Units hunt, diverge, or circulate reactive current | Simulated and energized functional tests |
| Blocking and alarms | Low voltage, overcurrent, drive trouble, tap limits, protection trips | Tap change occurs during an unsafe system condition | Cause-and-effect test with timestamped records |
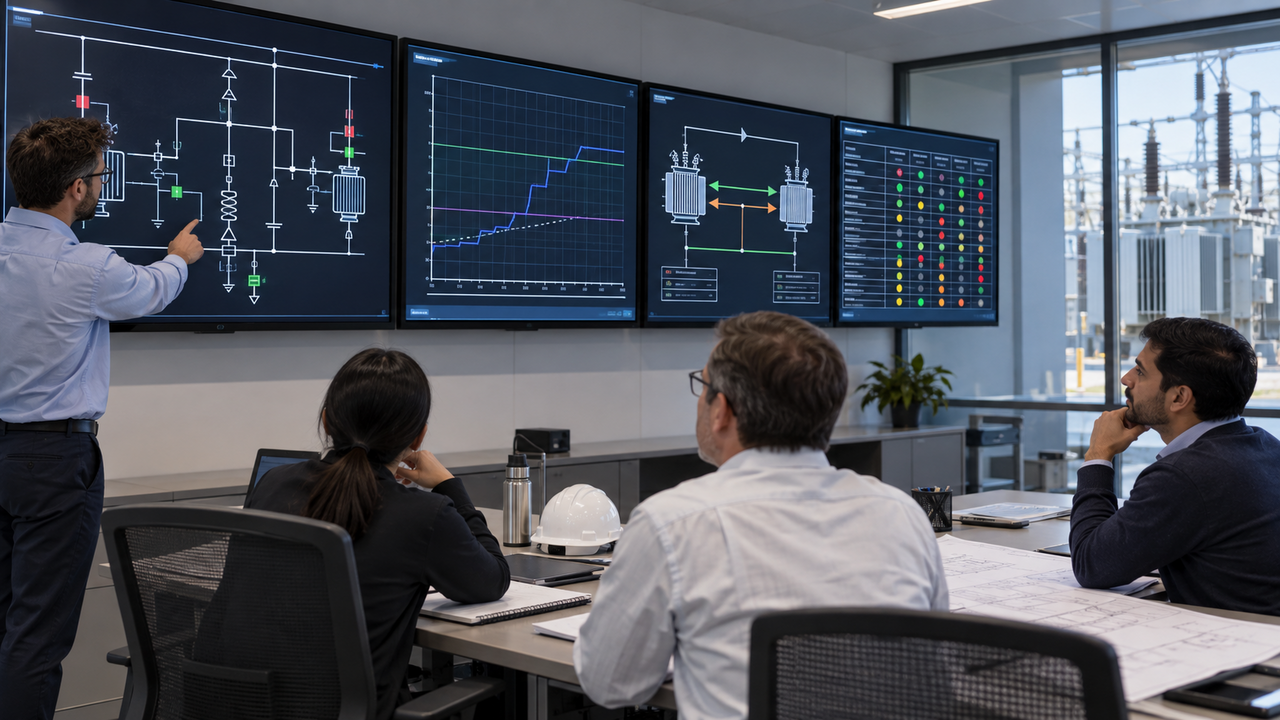
The AVR cannot regulate better than its measurement. Identify the VT winding, ratio, accuracy class, burden, phase arrangement, fuse or MCB supervision, and the point represented by the signal. If voltage comes through a bay controller or merging device, define scaling, quality flags, update rate, loss-of-signal behavior, and fallback mode. Avoid using an unspecified “bus voltage” tag that may change source during bus transfer.
Define the target voltage, deadband, initial delay, inter-tap delay, and maximum operations within a time window. Settings should prevent unnecessary hunting while meeting the network voltage requirement. Line-drop compensation needs feeder resistance and reactance assumptions, current measurement polarity, and sensible limits. If the controlled bus can be energized from another source, explain when the AVR is enabled and how reverse power or open-breaker conditions affect control.
Related EPC controls should remain coordinated with the transformer protection interface matrix. Protection trips, high current, low voltage, incomplete sequence, tap-changer pressure operation, and maintenance modes may block automatic movement, but each block should be justified and annunciated. An invisible permanent block is nearly as harmful as no block.
For hardwired commands, define wet or dry contacts, nominal control voltage, contact rating, pulse or maintained logic, common return, electrical isolation, and fail-safe state. Confirm which direction is “raise”: raising tap number does not always mean raising secondary voltage, depending on winding location and naming convention. Schematics, nameplates, HMI arrows, and operating instructions must use one agreed convention.
Tap position may be transmitted through resistance, potentiometer, BCD contacts, 4–20 mA, digital protocol, or a separate transmitter. State the mapping for every physical position, including transition or out-of-step states. The AVR, local indicator, relay, bay controller, and SCADA historian should display the same number. If the HMI shows ratio or secondary voltage instead of tap number, define the conversion and rounding.
At minimum, review tap-changer in progress, drive supply failure, motor protection operation, incomplete step, upper limit, lower limit, local mode, remote mode, heater failure where monitored, pressure or oil-flow protection where provided, and maintenance due counter. Use the project’s alarm philosophy to decide which conditions trip, block, alarm, or only indicate. The technical interface closure process should link every signal to a schematic, terminal, cable core, I/O point, SCADA text, and test sheet.
Parallel operation requires compatible ratios, vector groups, phase displacement, impedance, tap steps, and control behavior. The EPC study should define whether units remain on the same tap, follow a master, minimize circulating current, or share reactive load. A simple master-follower scheme can work for matched transformers, but it needs loss-of-master behavior, communication supervision, and a rule for changing the master.
Circulating-current or reactive-current methods require correctly polarized current inputs and stable settings. Define how the controller responds when one transformer is out of service, a bus coupler changes state, or a CT circuit is unavailable. Interlocks should use proven breaker and isolator status with quality supervision. Avoid automatic grouping based only on an operator’s assumption that two transformers are connected in parallel.
For new and existing transformers, compare tap tables rather than only the nominal ratio. Different step counts or neutral positions may prevent direct follower operation. Study credible combinations across the permitted range and set mismatch limits. The previously published vector group selection guidance should be applied together with ratio and impedance compatibility; phase displacement alone does not guarantee acceptable parallel loading.
Remote tap control is an operational command, not merely a monitoring point. Define authorization, local/remote selection, command validation, select-before-operate behavior where required, timeout, duplicate-command rejection, and event recording. Networked controllers should follow the owner’s cybersecurity architecture, user-access policy, time synchronization, and change-management process. The transformer vendor should not create an unmanaged remote path around the station control system.
SCADA should show tap position, control mode, in-progress status, limits, AVR enabled, blocked reason, voltage target, and significant drive alarms. Sequence-of-events resolution should be sufficient to reconstruct a failed operation. Agree signal descriptions early so FAT databases, site HMI, drawings, and operating manuals use identical terminology.
Protection interaction needs a cause-and-effect matrix. High current may block tap movement to protect contacts during severe load or fault conditions; undervoltage blocking may prevent an AVR from chasing a collapsed system; pressure devices may trip the transformer. Exact functions depend on the tap changer and system study. Never copy thresholds from another project without checking rated through-current, fault behavior, controller design, and operating philosophy.
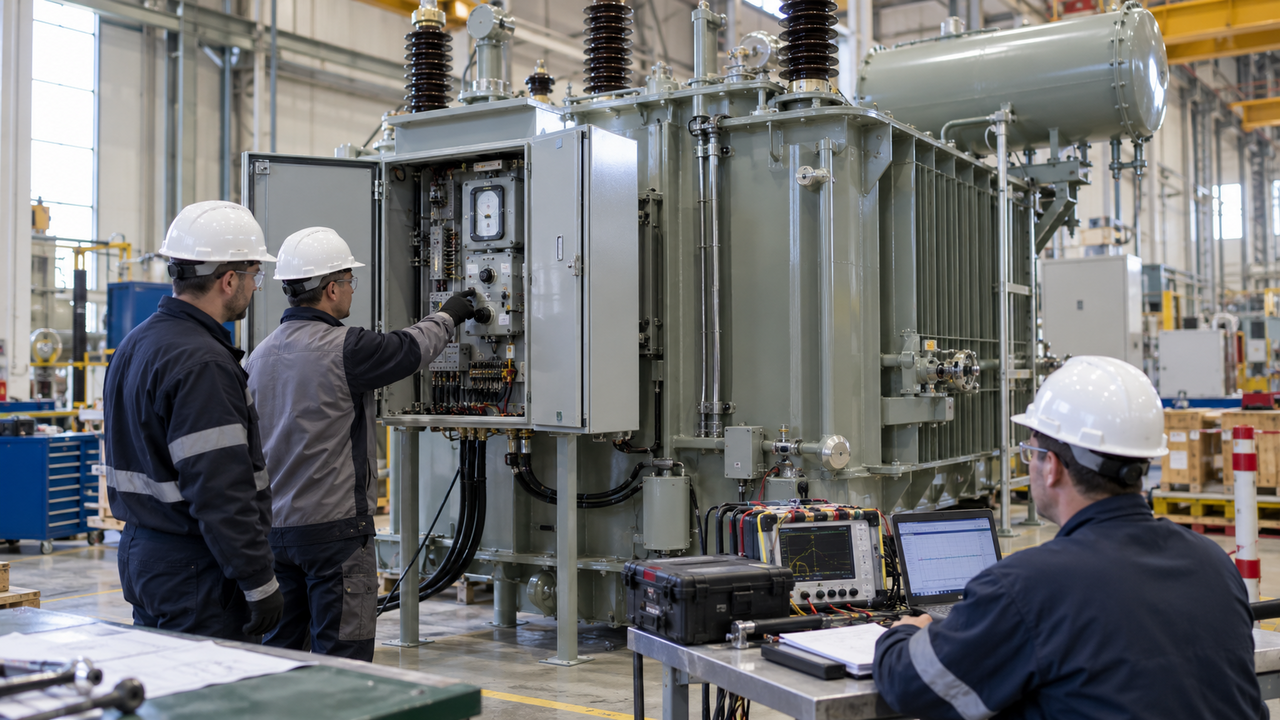
Factory testing should cover mechanical operation through the full range, local raise and lower, hand-crank interlock, limit switches, operation counter, position indication, motor and heater circuits, supply-failure alarms, and terminal continuity. Verify command direction against the approved tap table. Where the AVR or bay controller is supplied separately, use a simulator or witness a panel integration test so the agreed interface is demonstrated before shipment.
Test each important signal from the initiating device to the marshalling terminal, not only by forcing an output relay. Record contact state in normal and alarm conditions. Demonstrate incomplete-operation logic, local/remote priority, command blocking, and recovery after supply interruption. Check terminal numbers and spare cores against drawings. FAT evidence should be revision-controlled and included in the manufacturing record dossier.
For transformer selection, a project may consider an 133 kV/135 kV three-phase power transformer or a 110 kV/115 kV power transformer, but the OLTC range, drive, control voltage, and interface list must be engineered for the specific network. Catalogue availability is not a substitute for an approved control philosophy.
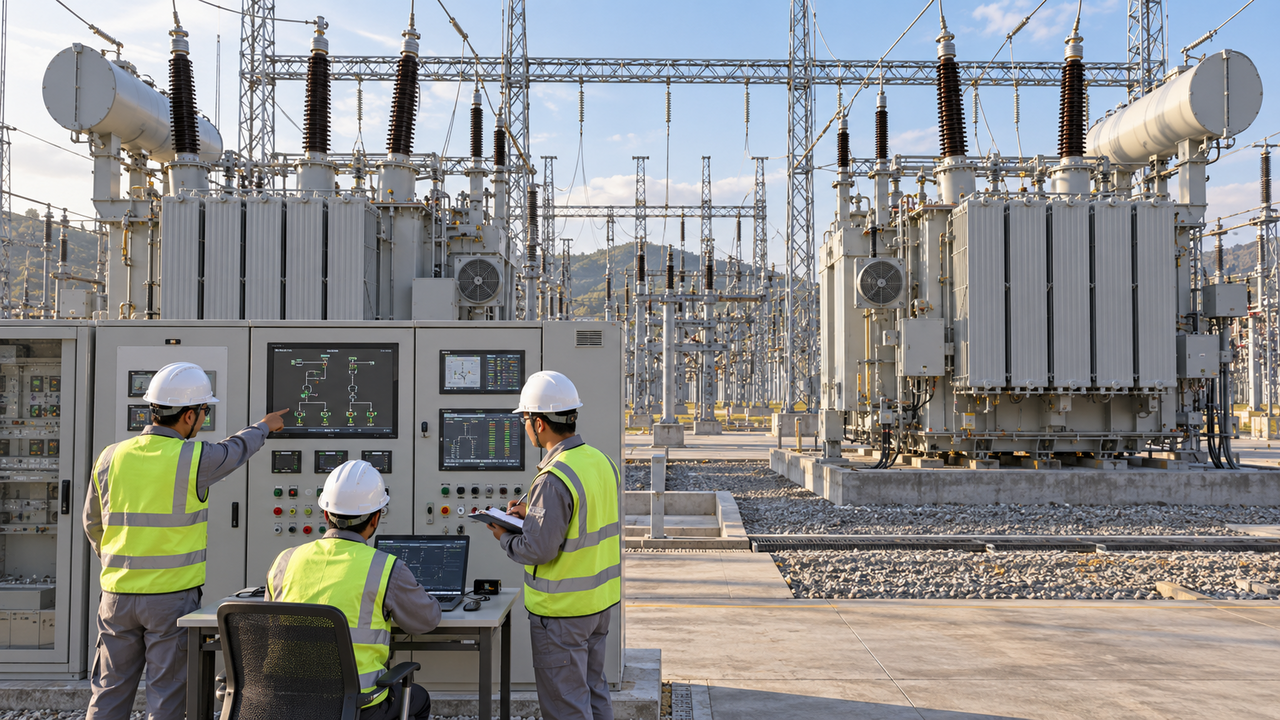
Site commissioning should begin with mechanical inspection, oil and drive checks, auxiliary-supply verification, insulation checks on control wiring, and confirmation that transport locks are removed. Point-to-point test every command, indication, alarm, and block. Inject the VT and CT circuits to prove polarity, scaling, line-drop compensation, and loss-of-signal behavior. Confirm time synchronization and event stamps across the AVR, relay, bay controller, and SCADA.
Before energized automatic operation, test local manual, remote manual, AVR manual, and automatic modes under controlled conditions. For parallel units, simulate grouping states and communication failures, then perform an energized trial with approved limits and close supervision. Verify that a commanded raise produces the expected controlled-bus response. Include rollback criteria if voltage, reactive sharing, circulating current, or tap mismatch exceeds the study limit.
The energization package should incorporate the substation pre-energization readiness review: approved settings, closed punch items, final tap position, transformer ratio, breaker status logic, SCADA readiness, operator briefing, and permission to enable automatic control. Do not enable the AVR merely because the transformer is energized.
The final dossier should include the approved tap table, schematics, terminal plans, signal list, AVR settings and rationale, parallel-control settings, software or firmware versions, test reports, alarm matrix, operating instructions, maintenance intervals, operation count baseline, and spare-parts list. Record as-left tap positions and active control modes. Any temporary commissioning override must have an owner and removal deadline.
Zisheng Electric can review transformer drawings, data sheets, load lists, technical specifications, single-line diagrams, grid parameters, environmental data, and installation-site conditions to configure the transformer OLTC control interface for the actual EPC project. Submit the voltage-control philosophy, VT and CT data, auxiliary supplies, SCADA protocol, protection cause-and-effect, parallel operating cases, and commissioning sequence with the equipment inquiry. Our engineering team will review the requirements and respond to project inquiries within 24 hours.
Transformer bushing specification guide for EPC substations covering rated voltage and current, insulation levels, creepage distance, CT terminal interfaces, dimensional checks, FAT evidence and commissioning acceptance.
View details
Build a transformer protection interface matrix covering CTs, relays, trips, alarms, SCADA, auxiliary power, FAT and commissioning responsibilities.
View details
Build a transformer spare parts strategy for EPC projects covering commissioning consumables, operational and insurance spares, storage, FAT and handover.
View details
Plan substation arc flash study inputs for EPC projects: source fault data, transformer impedance, switchgear geometry, protection settings and as-left handover.
View details